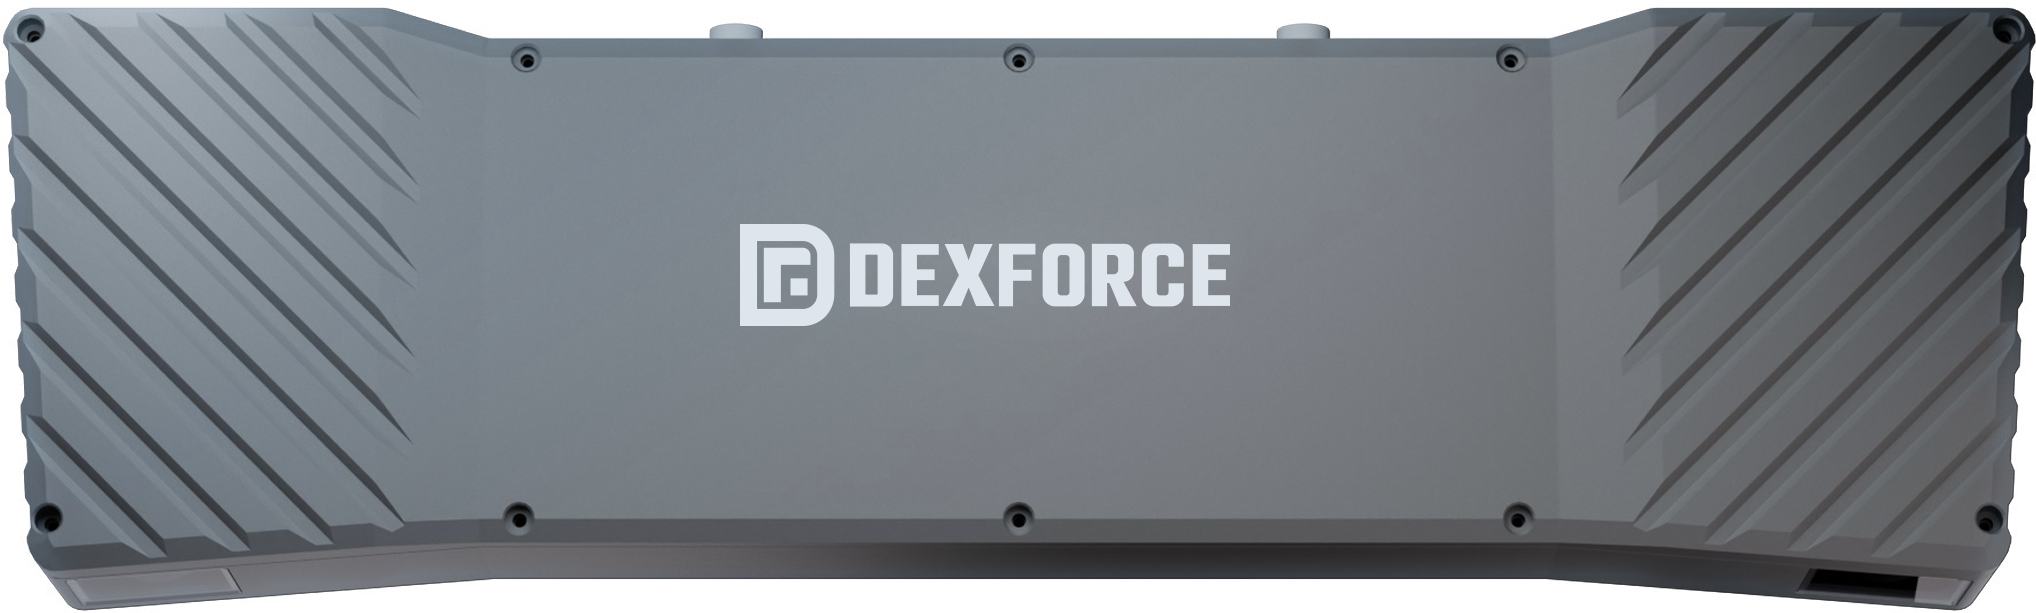

- A passive stereo solution delivers accurate 3D reconstruction of complex parts.
- Reliably captures complete 3D data for irregular structures, curved surfaces, and angular parts.
Redefining robot precision and speed with AI vision
AI powered for complex surfaces in harsh conditions
KINGFISHER-S-601

- The proprietary DexVerse engine addresses imaging challenges with transparent, dark, and highly reflective objects.
- AI models extend imaging to materials that are hard for standard vision systems.

- Import CAD models directly, with no manual labeling.
- A streamlined vision-only design reduces hardware cost without compromising imaging quality.
Solutions
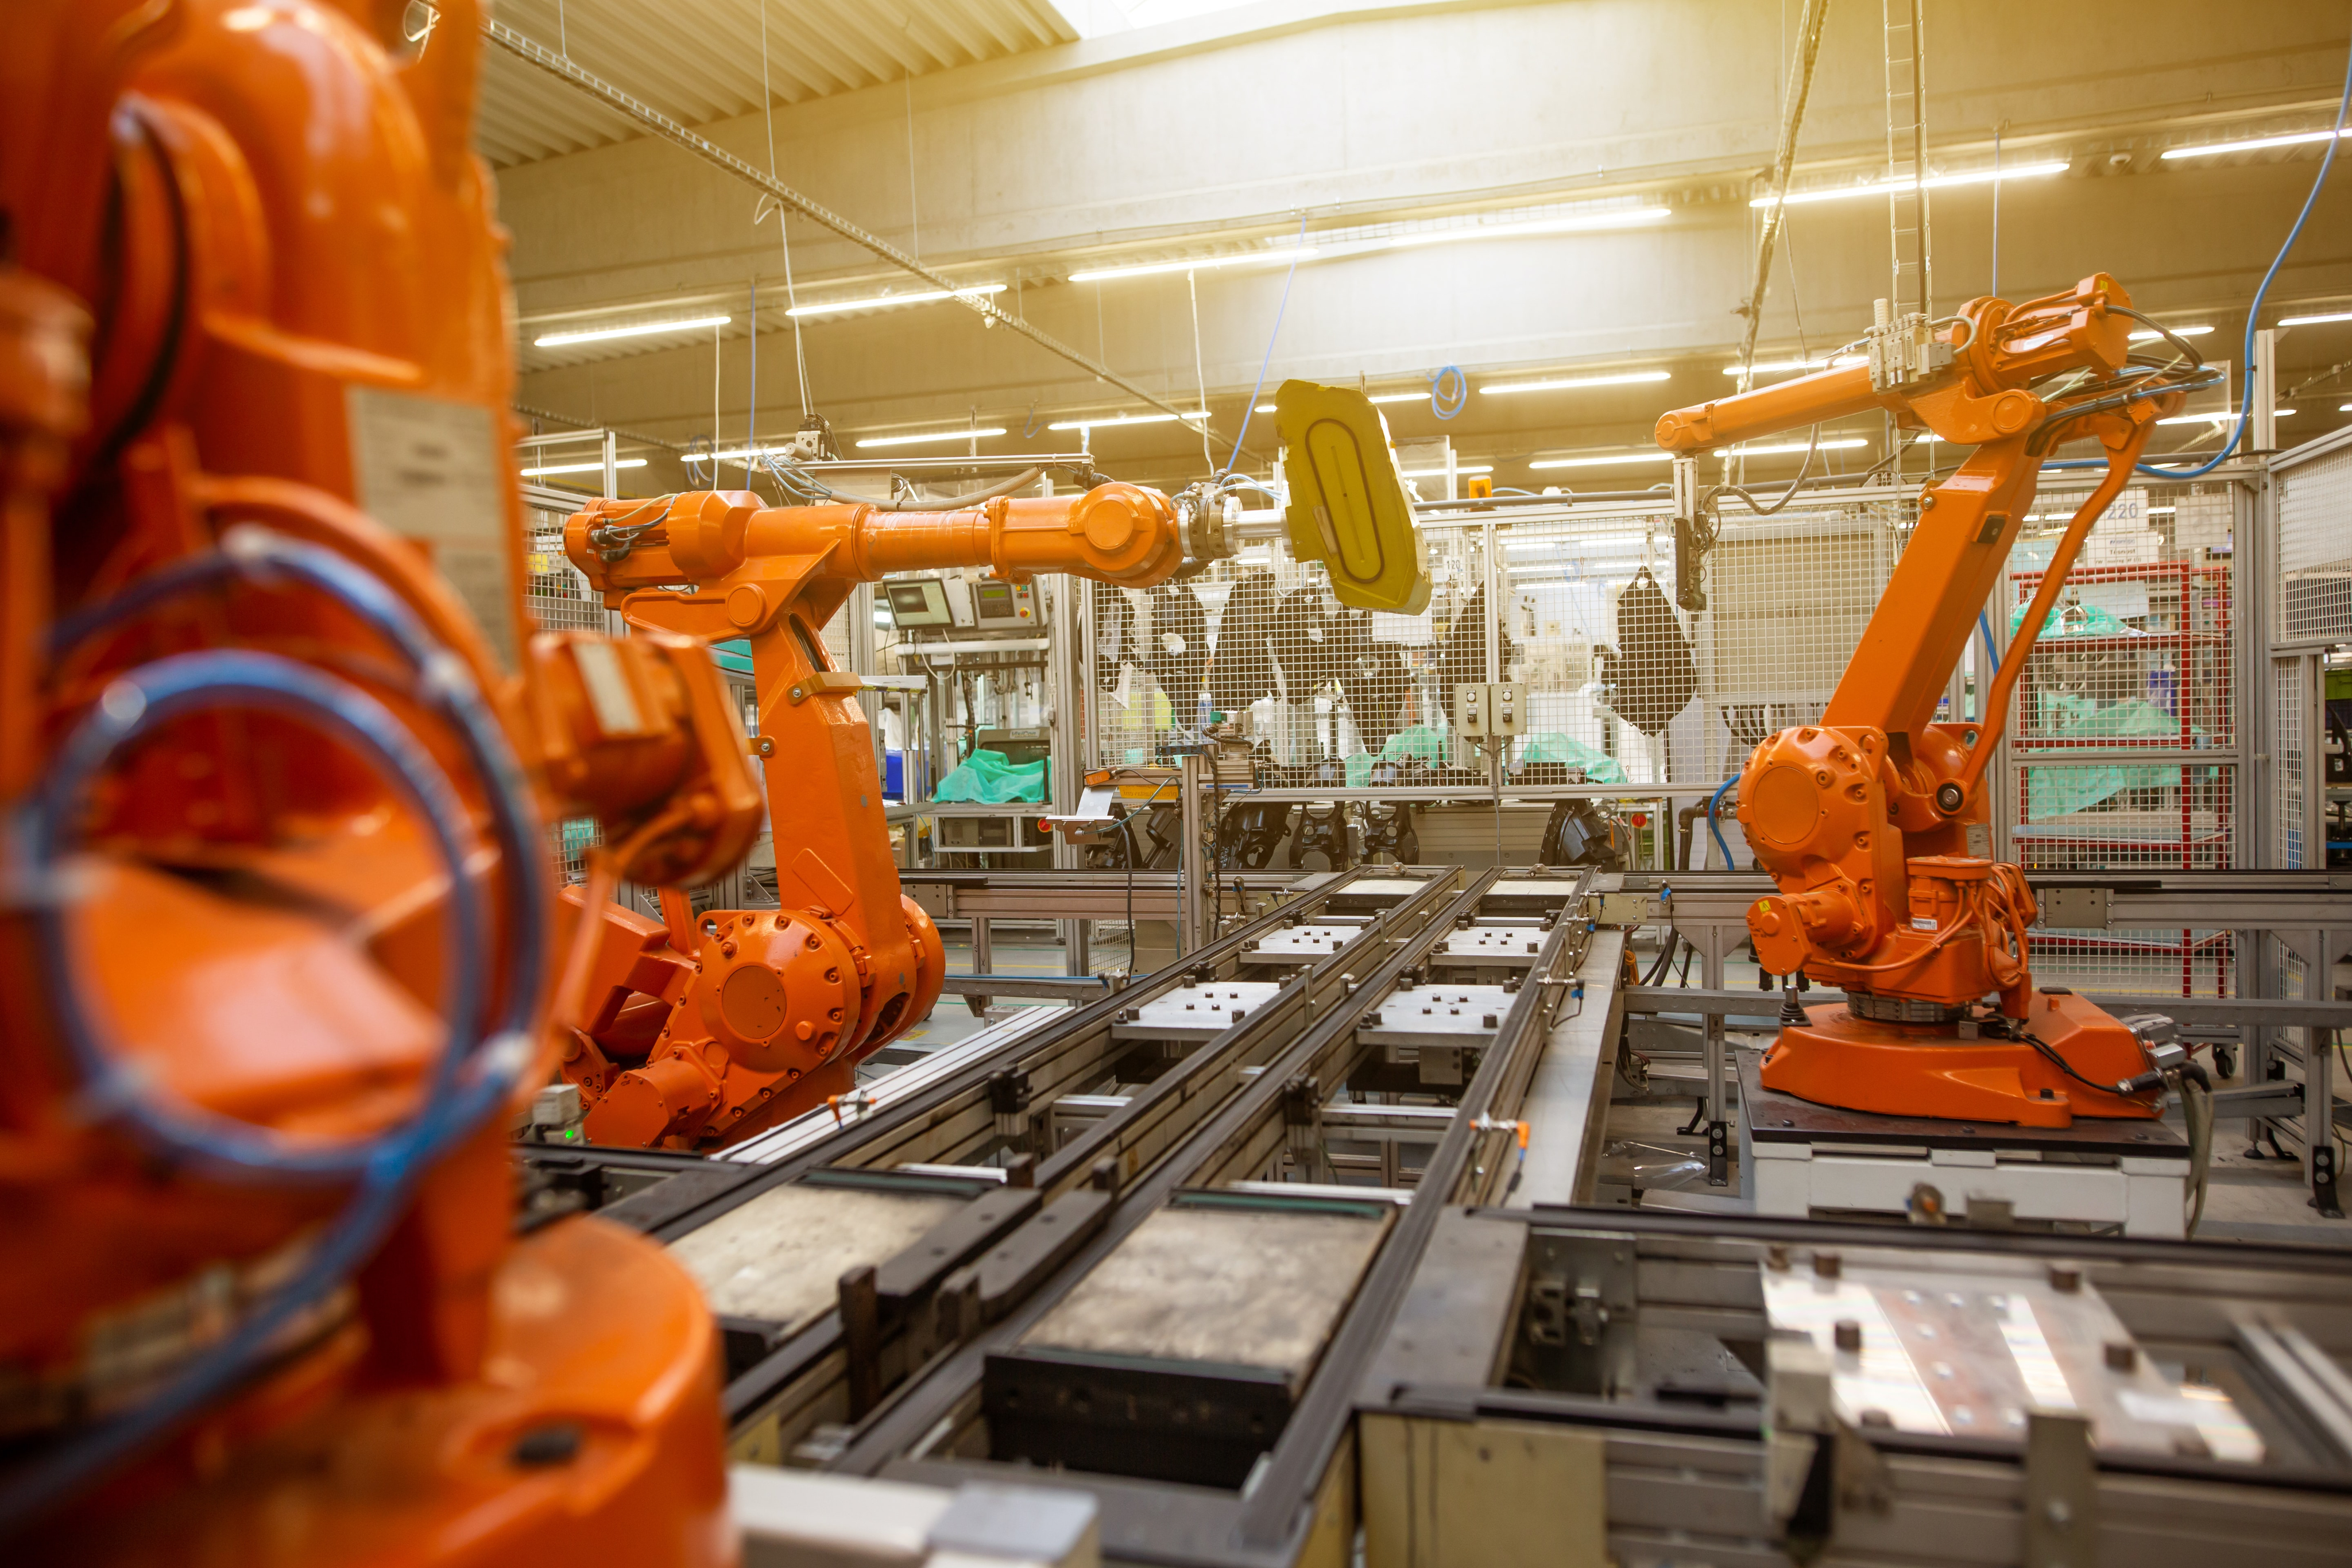
AI + 3D vision guided workpiece handling
AI + 3D vision guide robots to pick randomly stacked or closely packed parts from bins for transfer or further processing. The solution supports workpiece handling in automotive, logistics,construction machinery, and steel manufacturing.
Learn moreAI + 3D vision guided workpiece handling
AI + 3D vision guide robots to pick randomly stacked or closely packed parts from bins for transfer or further processing. The solution supports workpiece handling in automotive, logistics,construction machinery, and steel manufacturing.
Learn more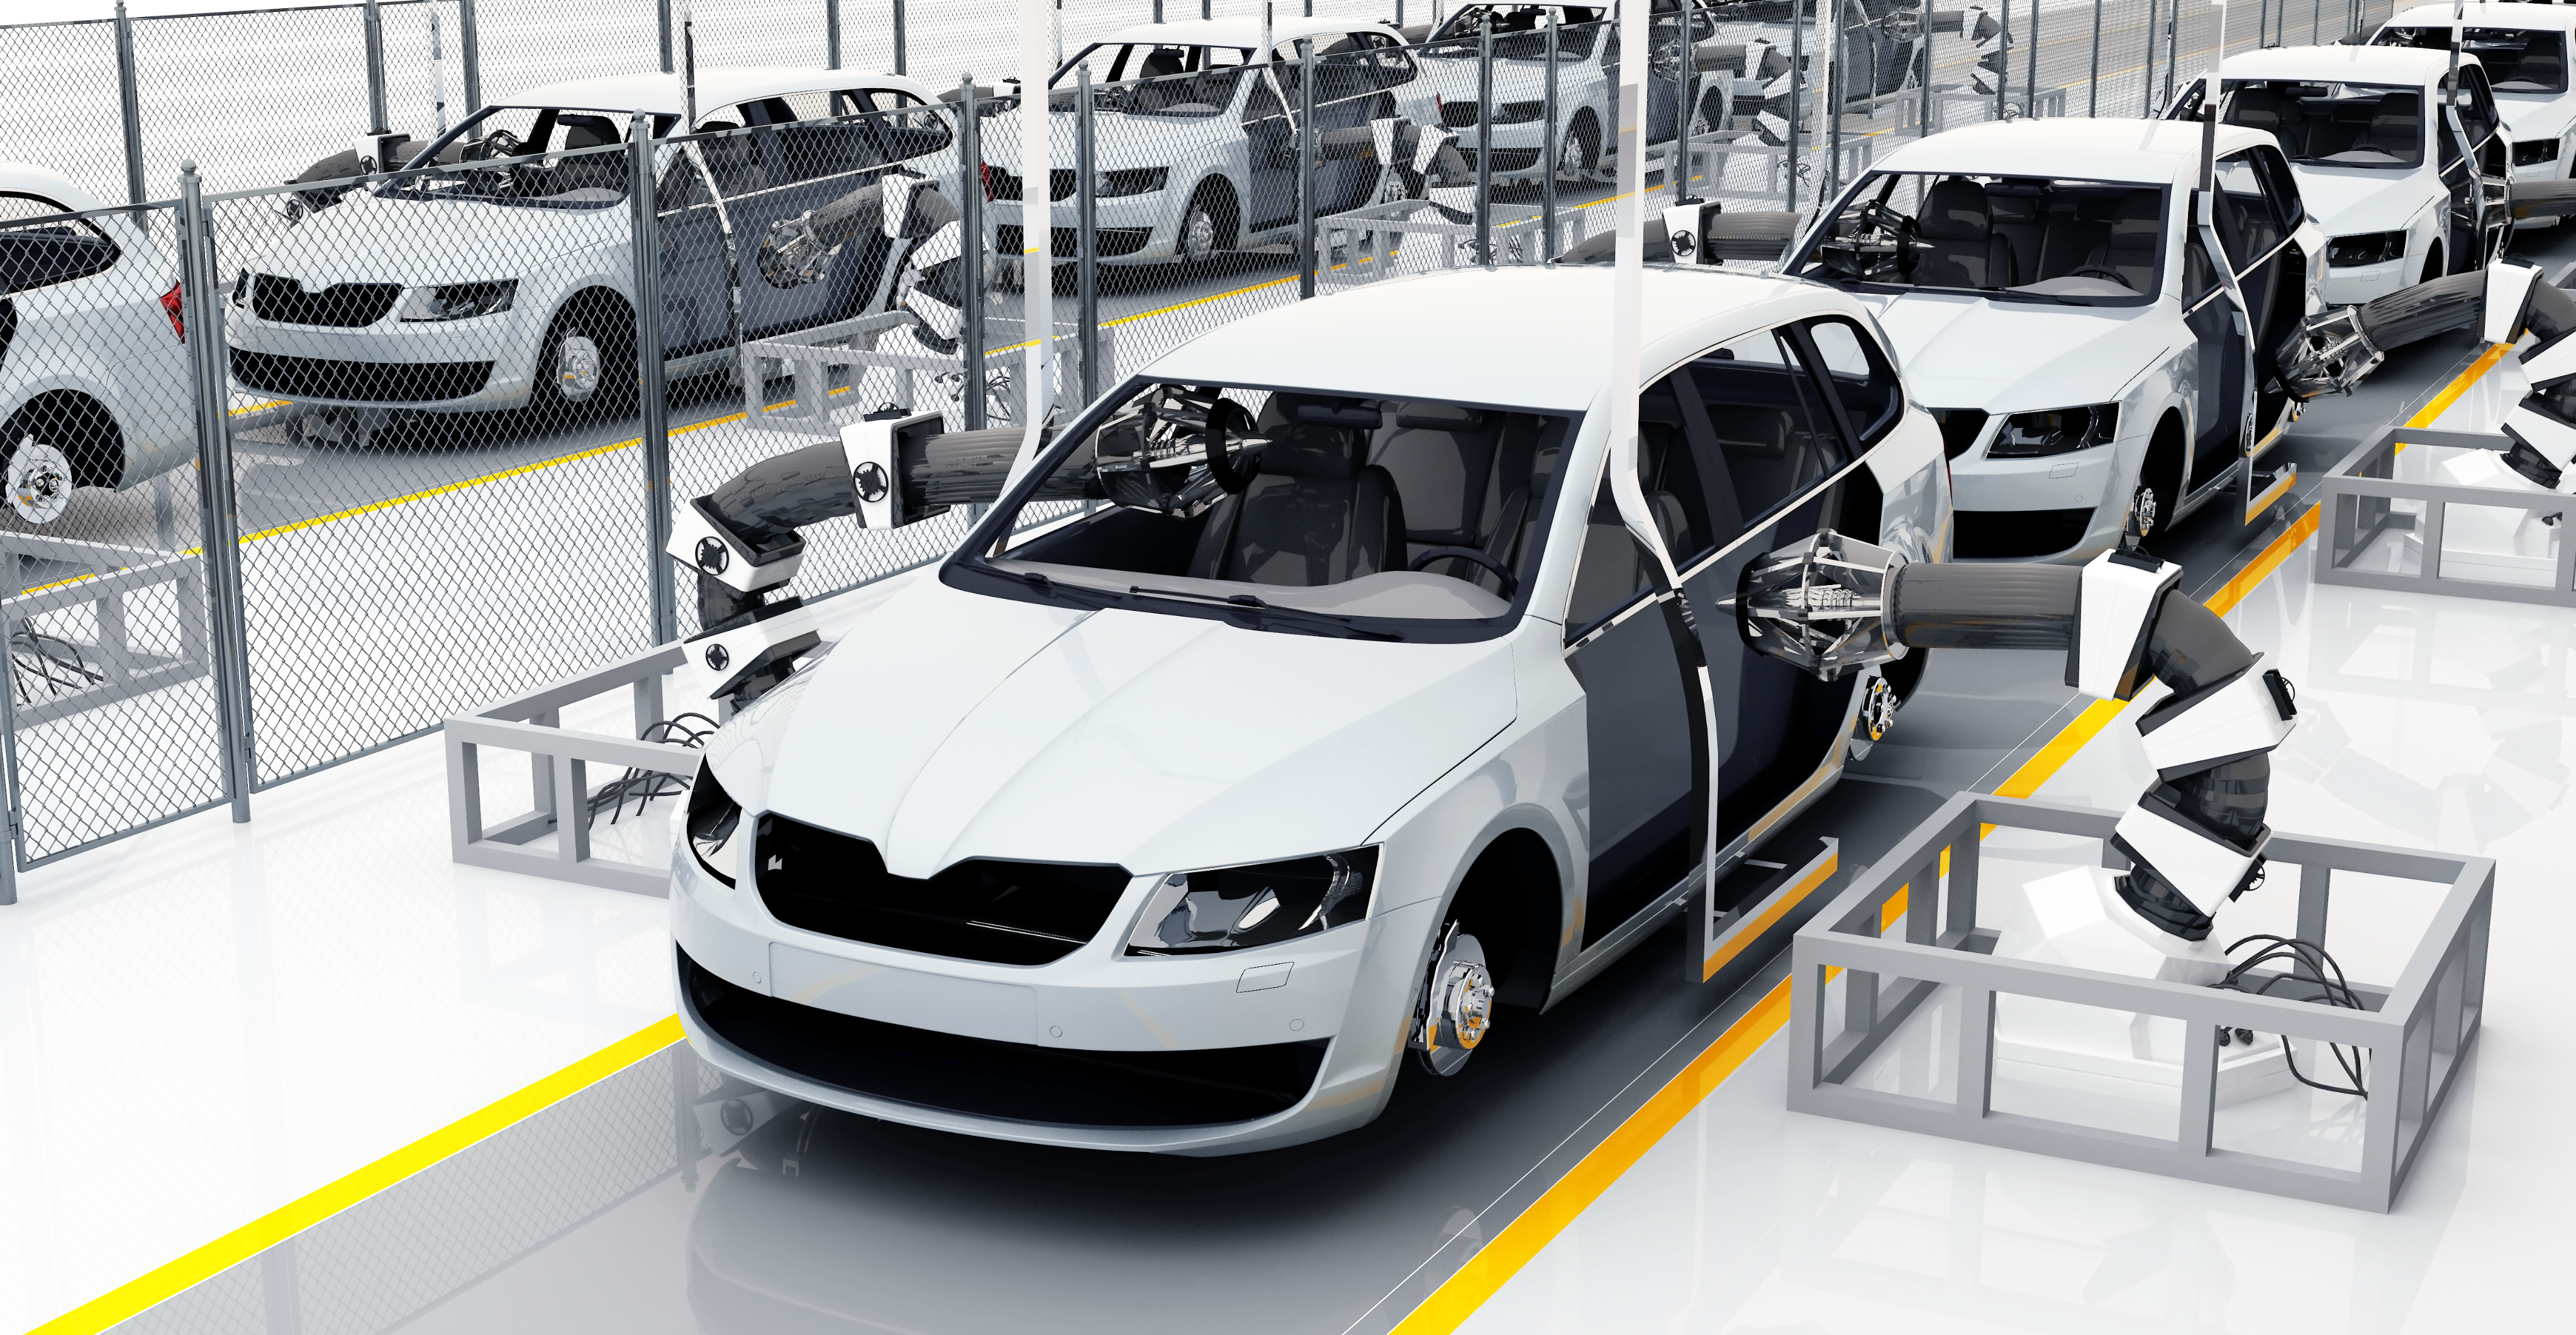
AI + 3D vision guided positioning and assembly
AI and 3D vision identify workpiece position and orientation in real time to guide precise picking, positioning, and assembly. It handles different part sizes and flexible production lines, improving assembly consistency and cutting changeover time.
Learn moreSpecifications
Product model
KINGFISHER-S-601
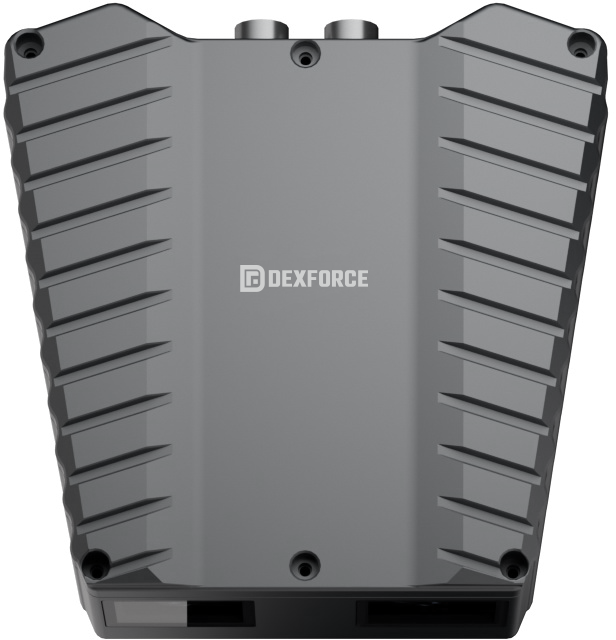
KINGFISHER-S-1001
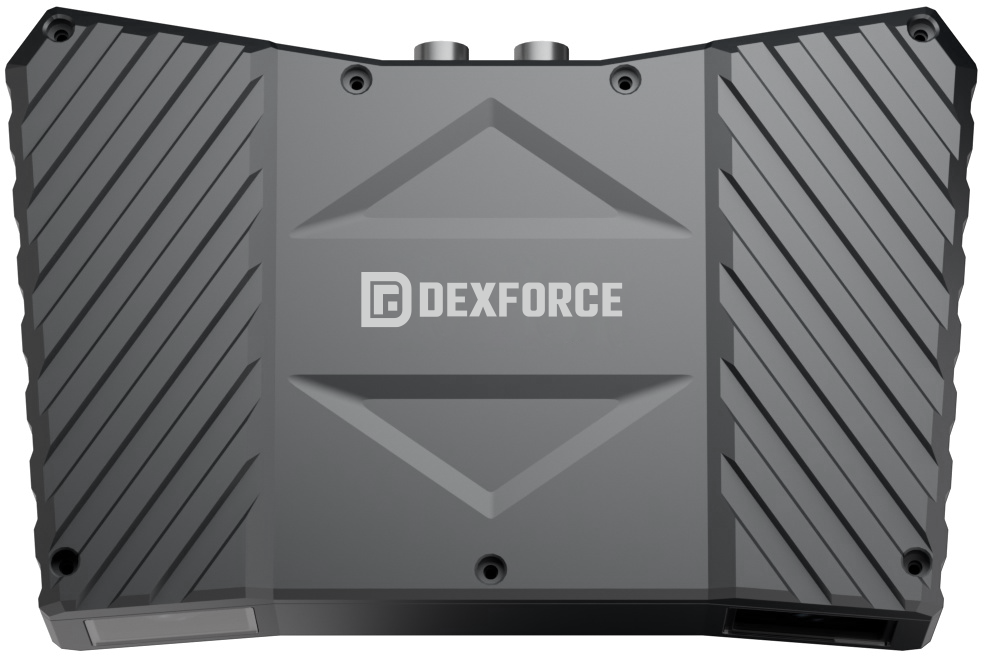
KINGFISHER-W-3003