Project Background
The automotive stamping workshop handles the forming of body structural parts and closure panels. Stamped parts are produced in large batches, across a wide range of specifications, and at heavy tonnage. The loading and unloading of stamped parts directly affects line cycle time and overall vehicle quality.
Project Challenges
Stamped body panels and structural parts arrive in bins in large batches and mixed specifications. Three factors made automation difficult as below:
- Low efficiency and inconsistent quality. Manual machine tending slows the line and makes quality hard to guarantee.
- Safety risks in a harsh environment. Heavy part handling in stamping workshops poses serious health risks to workers.
- Difficult imaging conditions. Stamped parts deform easily and often stick together or block each other. Reflective surfaces, oil contamination, and complex lighting cause frequent imaging defects for conventional vision systems.
Workflow
From 3D Perception to Robot Execution
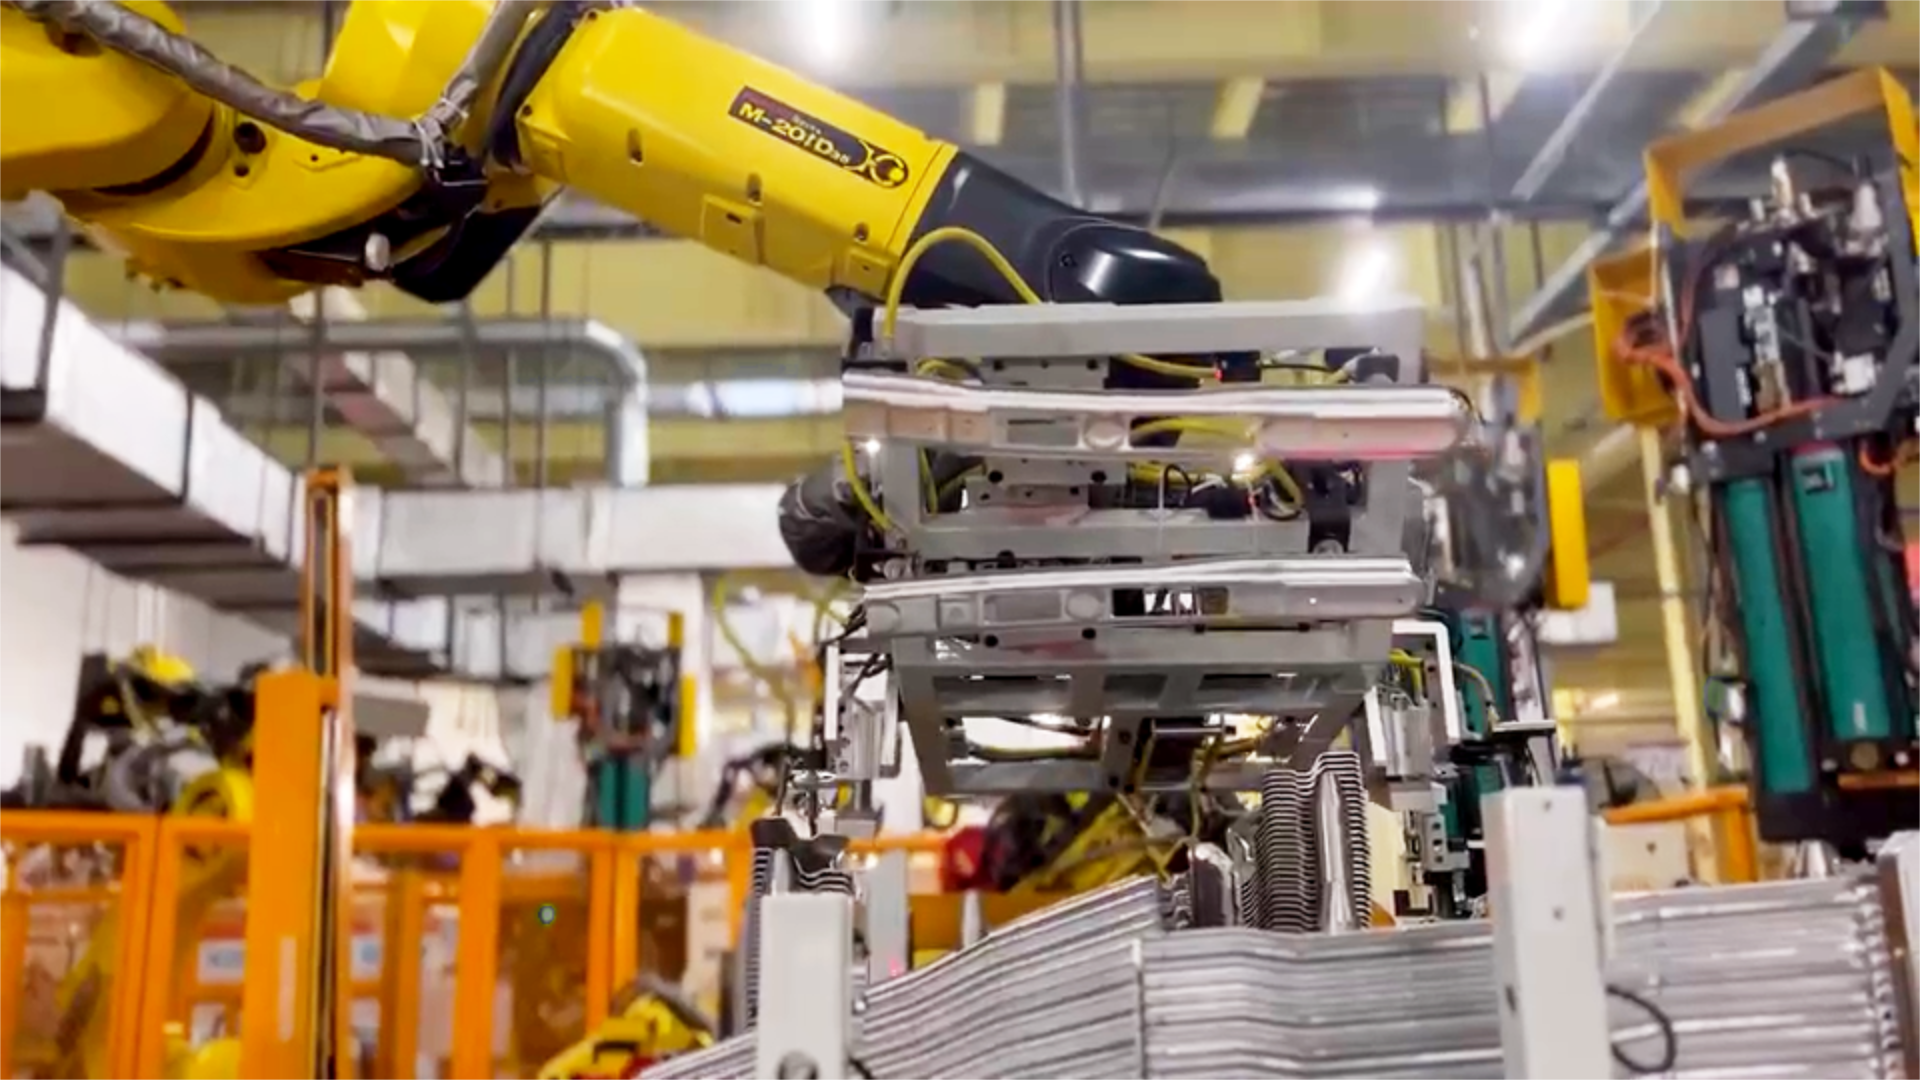
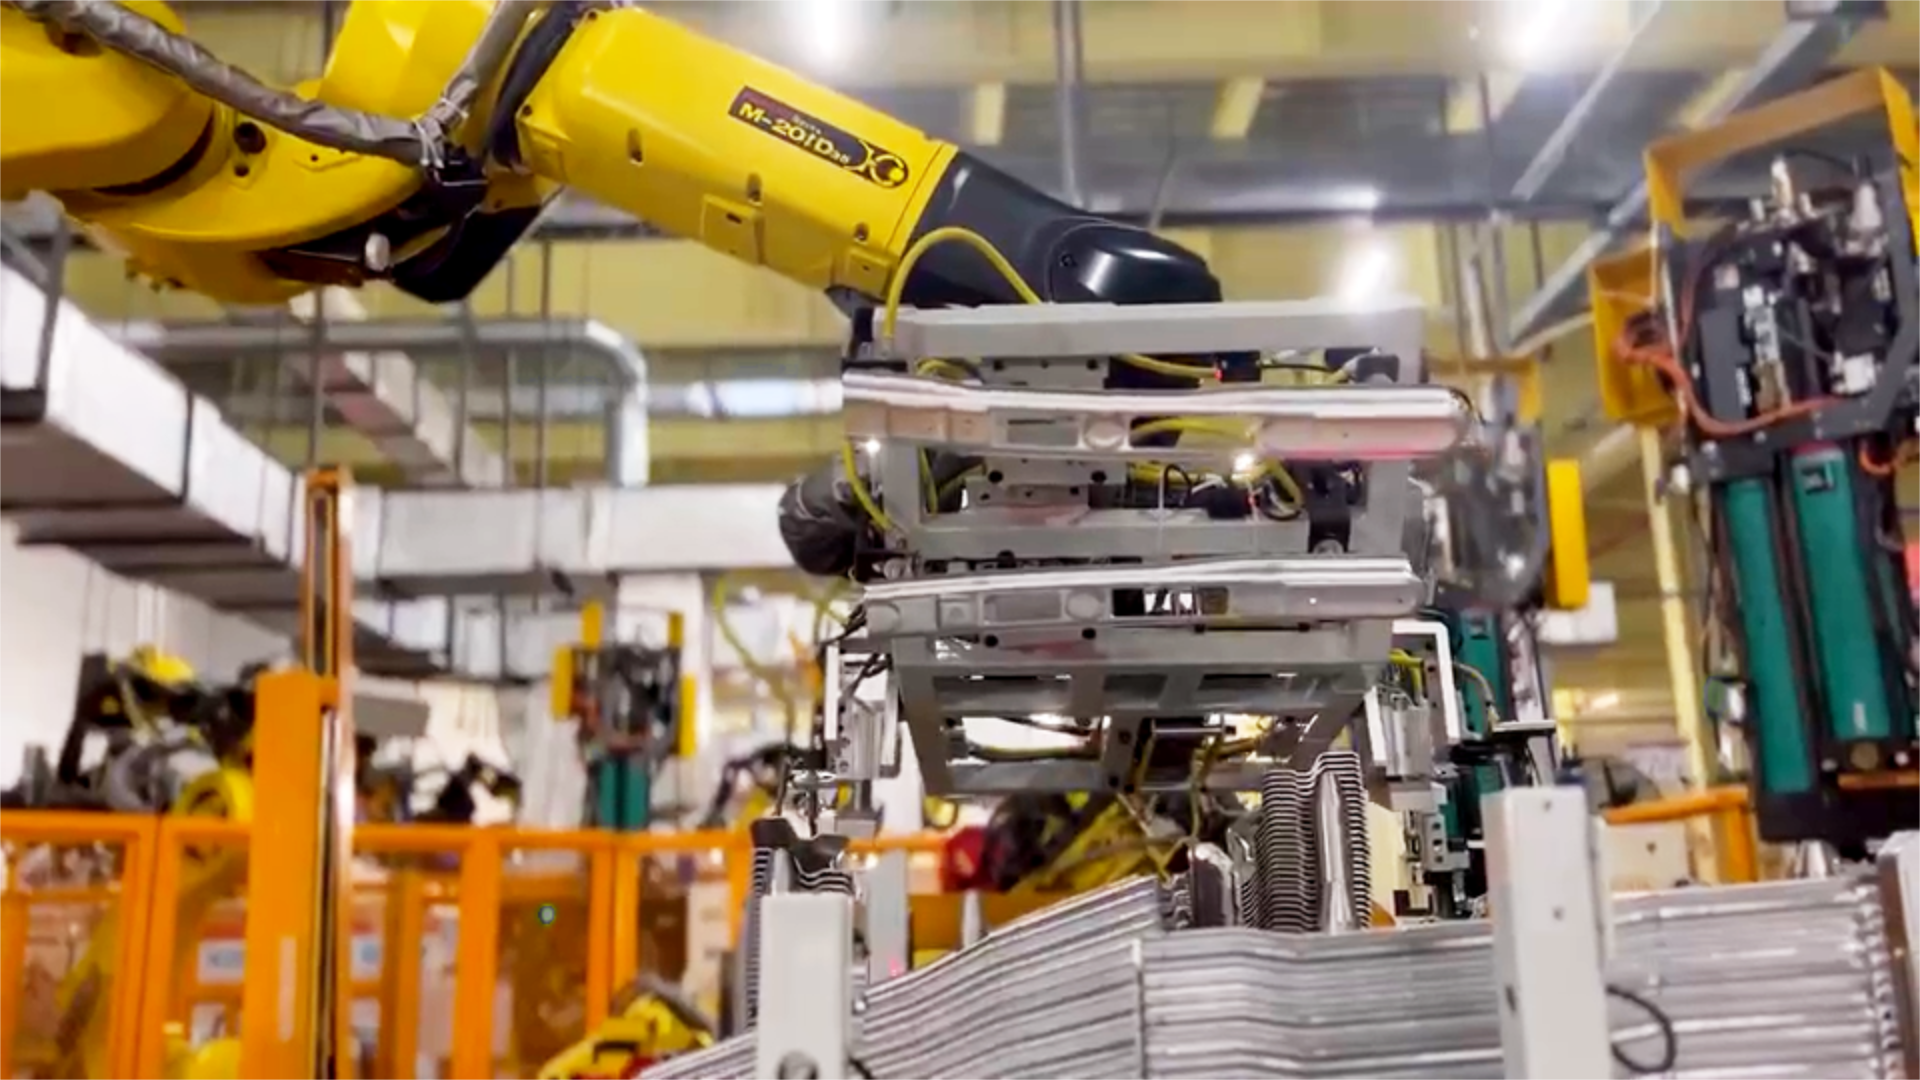
Built on the DexForce embodied AI architecture, the system performs fast 3D imaging of stamped parts inside the bin and outputs complete, high-quality point clouds. Target segmentation and 6D pose estimation run simultaneously to identify the optimal grasp candidate from unstructured, tightly stacked parts. The system then guides the industrial robot to precisely pick each stamped part and transfer the part to the stamping or welding station. Once processing is complete, finished parts are automatically unloaded and stacked in an orderly manner, closing the loop on unmanned machine tending.
Technical Advantages
- Reliable 3D imaging of reflective metal parts. The high-precision 3D camera generates high-quality point clouds of reflective stamped parts, with stable imaging performance under oil contamination and complex lighting.
- Sub-millimeter accuracy at full line speed. Visual positioning accuracy of ±0.6 mm and a cycle time of ≤2.8 s meet the demands of high-speed stamping lines.
- Robust picking of deformed and stacked parts. The algorithm handles deformed sheet metal and closely stacked irregular parts, significantly reducing the risk of pick failure.
Application Results
The DexForce spatial intelligence suite enabled 100% unmanned bin picking with 3D vision gives stamping plants a practical path to automate one of the most demanding steps in body production. Reliable point cloud imaging of reflective and deformed parts, sub-millimeter robot guidance, and fast vision cycle times allow a single station to handle mixed-model stamped part loading and unloading without manual intervention.